制御システム
R2026b制御システム エンジニアとして、プラントのモデル化、コントローラー設計、自動コード生成による展開、システム検証など、開発のあらゆる段階で MATLAB® および Simulink® を使用できます。MATLAB および Simulink 制御システム製品を使用して、以下を行うことができます。
基本モデル、システム同定、または自動パラメーター推定を使用した、線形および非線形プラント ダイナミクスのモデル化。
非線形 Simulink モデルの平衡化、線形化、およびその周波数応答の計算。
根軌跡、ボード線図、LQR、LQG などの設計手法を用いたプラント モデルに基づくコントローラー設計。
オーバーシュート、立ち上がり時間、位相余裕、ゲイン余裕など、時間領域と周波数領域におけるパフォーマンスおよび安定性特性を用いた、制御システムのパフォーマンスの対話的解析。
PID、ゲイン スケジュール、ならびに任意の SISO および MIMO 制御システムの自動調整。
ロバストなコントローラーやモデル予測コントローラーの設計と実装、あるいは、モデル参照適応制御、極値探索制御、強化学習、ファジィ論理など、モデルに依存しない制御法の利用。
組み込みシステムへの制御アルゴリズムの展開による、リアルタイム制御、調整、パラメーター推定。
状態監視および予知保全アルゴリズムの設計およびテスト。
制御システム 向け製品
Control System Toolbox
制御システムの設計と解析
System Identification Toolbox
入出力データからの線形および非線形の動的システム モデルの作成
Predictive Maintenance Toolbox
状態監視と予知保全のアルゴリズムの設計とテスト
Robust Control Toolbox
Design robust controllers for uncertain plants
Model Predictive Control Toolbox
Design and simulate model predictive controllers
Fuzzy Logic Toolbox
Design and simulate fuzzy logic systems
Simulink Control Design
モデルの線形化と制御システムの設計
Simulink Design Optimization
Analyze model sensitivity and tune model parameters
Reinforcement Learning Toolbox
強化学習を使用した方策の設計と学習
Motor Control Blockset
モーター制御アルゴリズムの設計と実装
C2000 Microcontroller Blockset
Texas Instruments C2000 マイクロコントローラー向けのアプリケーションの設計、シミュレーション、および実装
STM32 Microcontroller Blockset
Design, simulate, and implement applications for STMicroelectronics STM32 microcontrollers
Raspberry Pi Blockset
Design, simulate, and deploy applications for Raspberry Pi.
トピック
プラントのモデル化、システム同定、およびパラメーター推定
- モデル オブジェクトでの制御システム モデリング (Control System Toolbox)
モデル オブジェクトを使用して、制御システムを表すモデルを作成します。 - 多変数システムでのデータの解析とモデルの特定 (System Identification Toolbox)
MIMO データを収集し、モデルを推定および比較し、対応するモデルの応答を表示する。 - 時変システム ダイナミクスを追跡するための ARX によるオンライン パラメーター推定 (System Identification Toolbox)
時変 ARX モデルのオンライン パラメーター推定を MATLAB コマンド ラインで実行する。 - Inverted Pendulum Parameter Estimation (Simulink Design Optimization)
Estimate multiple parameters of a model by iterated estimations.
平衡化、線形化、および周波数応答の推定
- 定常状態マネージャーを使用した仕様からの操作点の計算 (Simulink Control Design)
定常状態マネージャー アプリを使って Simulink モデルを平衡化することにより、仕様を満たす定常状態の操作点を検出する。 - Simulink モデルのモデル操作点での線形化 (Simulink Control Design)
初期状態値と入力信号から構成されている操作点でモデルを線形化します。 - モデル線形化器での 2 値疑似乱数列を使用した周波数応答の推定 (Simulink Control Design)
モデル線形化器で PRBS 入力信号を使用して高周波数のパワー エレクトロニクス システムの周波数領域モデルを同定する。
制御設計と調整
- 根軌跡の設計 (Control System Toolbox)
根軌跡のグラフィカルな調整手法を使用して、電気油圧サーボ機構の補償器を設計する。 - 自動調整法を使用した補償器の設計 (Control System Toolbox)
制御システム デザイナーで自動調整法を使用して補償器を調整する。 - systune を使用した制御システムの調整 (Control System Toolbox)
systuneを使用して、シンプルなアプリケーション用に構成されたコントローラーを調整する。 - シミュレートされた I/O データを使用したパワー エレクトロニクス モデルのコントローラーの設計 (Simulink Control Design)
PID 調整器を使用してプラント モデルを特定し、線形化できないパワー エレクトロニクス モデルの PID コントローラーを設計します。 - Closed-Loop PID Autotuner ブロックを使用したゲイン スケジュール コントローラーの調整 (Simulink Control Design)
Closed-Loop PID Autotuner ブロックを使用して水タンク モデルのゲイン スケジュール PID コントローラーを 1 回のシミュレーションで調整する。
予測制御とロバスト制御
- Design MPC Controller in Simulink (Model Predictive Control Toolbox)
Design and simulate a model predictive controller for a Simulink model using MPC Designer. - Robust Control of Active Suspension (Robust Control Toolbox)
In this example, use H∞ synthesis to design a controller for a nominal plant model. Then, use μ synthesis to design a robust controller that accounts for uncertainty in the model.
適応制御とインテリジェント制御
- ウイング ロックが発生した航空機のモデル規範形適応制御 (Simulink Control Design)
外乱モデルのパラメーターを適応させることで理想の参照モデルに匹敵する性能を実現する、MRAC コントローラーを設計する。 - 強化学習デザイナーを使用したエージェントの設計と学習 (Reinforcement Learning Toolbox)
強化学習デザイナー アプリを使用して、カートポール システム用の DQN エージェントの設計および学習を行う。 - Design Controller for Artificial Pancreas Using Fuzzy Logic (Fuzzy Logic Toolbox)
Design and tune a FIS tree to control insulin infusion for type-1 diabetes.
展開可能なアルゴリズム
- Tune PI Controllers Using Field Oriented Control Autotuner Block on Real-Time Systems (Motor Control Blockset)
Compute the gain values of PI controllers within the speed and current controllers by using the Field Oriented Control Autotuner block. - Simulation and Code Generation Using Simulink Coder (Model Predictive Control Toolbox)
Simulate your MPC controller in Simulink and generate real-time code that uses either double-precision or single-precision signals. - Parameter Tuning for Digital Twins (Simulink Design Optimization)
Monitor the condition of an electric vehicle battery in the field with a deployed version of parameter estimation using Simulink Compiler™.
注目の例

ヘリコプターのマルチループ制御
slTuner と systune を使用して、回転翼航空機のマルチループ コントローラーを調整する。

Closed-Loop PID Autotuner ブロックを使用した三相整流器の PID コントローラーの設計
Closed-Loop PID Autotuner ブロックを使用して Vienna 整流器ベースの力率修正器のコントローラーを調整する。

極値探索制御を使用したアダプティブ クルーズ コントロール
アダプティブ クルーズ コントロール システムのコントローラー ゲインを調整するための極値探索コントローラーを設計する。

C2000 プロセッサを使用してデュアル モーター (Dyno) を搭載した PMSM を制御する
この例では、フィールド指向制御 (FOC) を使用して、ダイノ セットアップで結合された 2 つの 3 相永久磁石同期モーター (PMSM) を制御します。Motor 1 は閉ループ速度制御モードで動作します。Motor 2 は機械的に結合されているため、トルク制御モードで動作し、Motor 1 に負荷をかけます。この例を使用して、さまざまな負荷条件でモーターをテストできます。
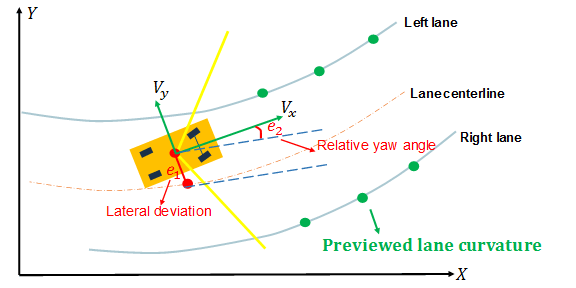
Lane Following Using Nonlinear Model Predictive Control
Design a lane-following controller using nonlinear MPC with road curvature previewing.

転動体ベアリングの故障診断
加速度信号に基づいて転動体ベアリングの故障診断を実行する。
ビデオ

カルマン フィルターを理解する
このビデオでは、カルマン フィルターの一般的な使用例について解説します。カルマン フィルターは、間接的かつ不確実な測定値からシステムの状態を推定するために使用される最適推定アルゴリズムです。
From PID Control to Adaptive Control: Systematically Designing Controllers in Simulink
このビデオでは、PID コントローラーからモデル規範形適応制御や強化学習ベースの制御まで、さまざまなタイプのコントローラーを体系的かつ自動化された方法で迅速に設計および実装する方法を紹介します。
Addressing Challenges Involved in Design and Implementation of Motor Control Algorithms
このビデオでは、システム レベルのシミュレーションを活用してモーター制御アルゴリズムを設計およびテストし、設計の複雑度を測定し、HIL 検証を含む体系的なユニット テストを実行する方法を紹介します。

