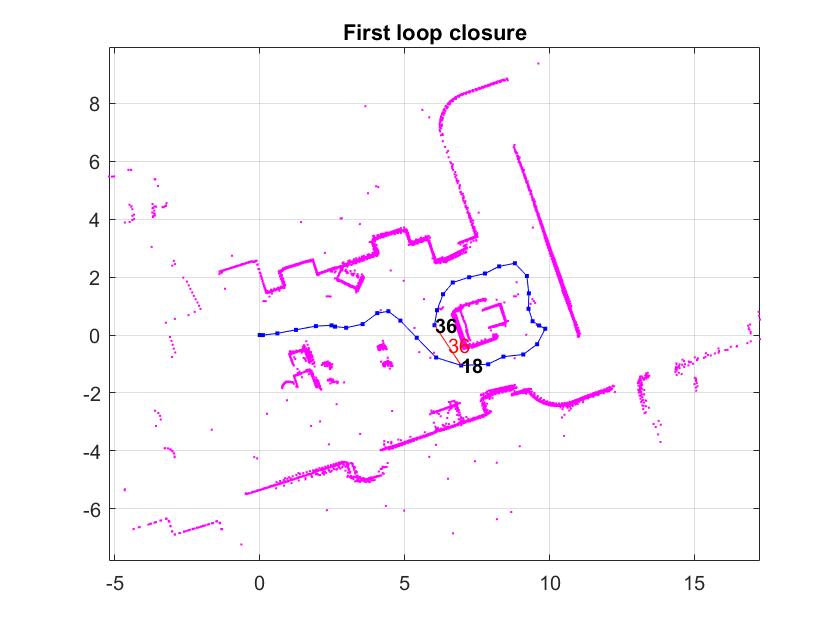
Implement Simultaneous Localization and Mapping (SLAM) with
Develop a map of an environment and localize the pose of a robot for autonomous navigation.

現在この提出コンテンツをフォロー中です。
- フォローしているコンテンツ フィードに更新が表示されます。
- コミュニケーション基本設定に応じて電子メールを受け取ることができます
引用
Mihir Acharya (2026). Implement Simultaneous Localization and Mapping (SLAM) with (https://jp.mathworks.com/matlabcentral/fileexchange/66284-implement-simultaneous-localization-and-mapping-slam-with), MATLAB Central File Exchange. に取得済み.

