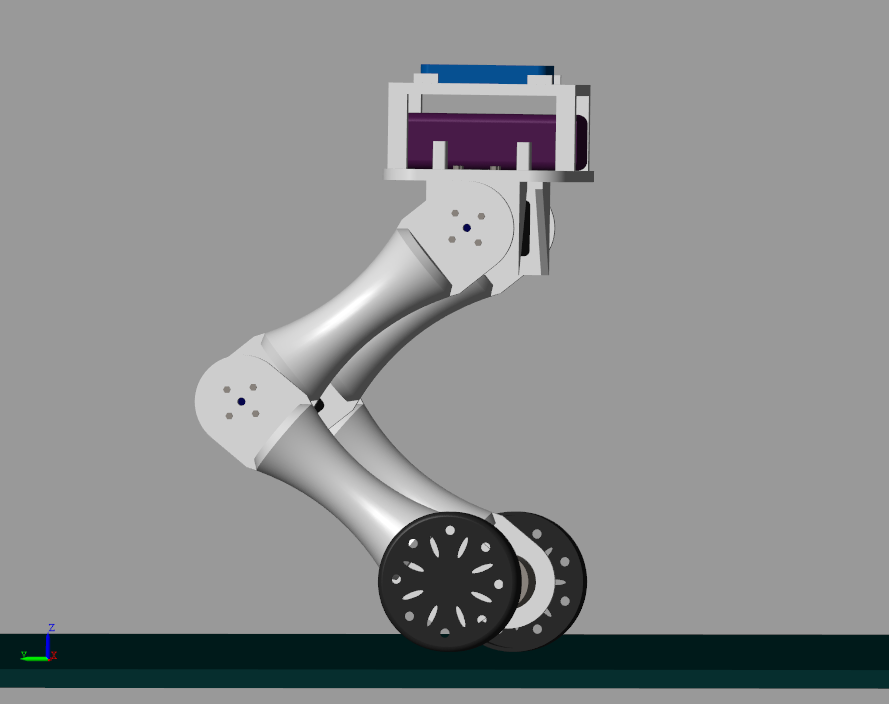
Modeling and Control of a Wheel-Legged Robot
This is a system made in Simscape, simulating a wheel-legged robot. Multiple joints work together to achieve self-balancing.

現在この提出コンテンツをフォロー中です。
- フォローしているコンテンツ フィードに更新が表示されます。
- コミュニケーション基本設定に応じて電子メールを受け取ることができます
引用
Aurel Marian (2026). Modeling and Control of a Wheel-Legged Robot (https://jp.mathworks.com/matlabcentral/fileexchange/116735-modeling-and-control-of-a-wheel-legged-robot), MATLAB Central File Exchange. に取得済み.

