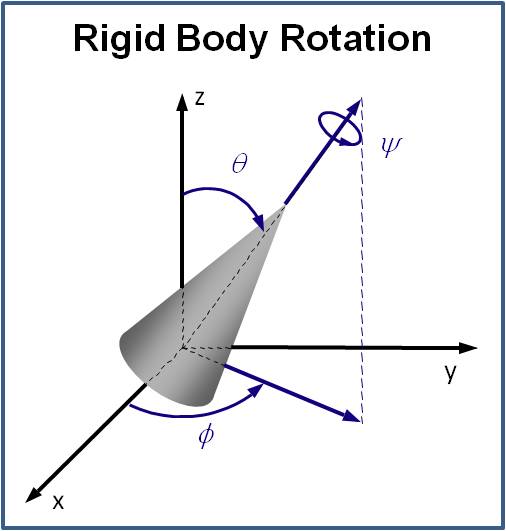
quaternion
quaternion class, vectorized, converts among rotation representations, numerical Euler propagation

現在この提出コンテンツをフォロー中です。
- フォローしているコンテンツ フィードに更新が表示されます。
- コミュニケーション基本設定に応じて電子メールを受け取ることができます
引用
Mark Tincknell (2026). quaternion (https://jp.mathworks.com/matlabcentral/fileexchange/33341-quaternion), MATLAB Central File Exchange. に取得済み.
| バージョン | 公開済み | リリース ノート | Action |
|---|---|---|---|
| 1.8.0 | Fixed bug noted by Nathan Pust (thank you!) in rotationmatrix, updated RotationMatix, updated OmegaAxis, fixed bug in equiv. |
||
| 1.7.0 | Changes: revised error messages, corrected repmat syntax
|
||
| 1.6.0 | Added missing unitvector function for OmegaAxis method |
||
| 1.5.0 | change normalize, rand; fix isequal*, rotateutov; add dot, interp1, randRot |
||
| 1.3.0 | added quaternion.OmegaAxis to get angular velocity vectors from time series of quaternions |
||
| 1.2.0 | A few new methods and small bug fixes |
||
| 1.1.0 | fixed bugs, added some new methods |
||
| 1.0.0 |

