インポート、エクスポート、可視化
R2026bツールボックスを使用して、MATLAB® で点群データのインポートと可視化が可能です。PLY、PCD、LAS、LAZ、E57、Ibeo データ コンテナー、Velodyne® PCAP、Ouster® PCAP、Hesai® PCAP など、さまざまなファイル形式からデータを読み取ることができます。
メモリに収まらない可能性がある大規模な点群データを処理するには、blockedPointCloud オブジェクトを使用して、より小さいブロックの集合として点群データを表し、それぞれを個別に処理できます。
また、処理済みのデータを PLY、PCD、LAS、および LAZ のファイル形式にエクスポートすることもできます。LiDAR データを操作する方法については、LiDAR 点群データの読み取り、処理、書き込みを参照してください。
アプリ
| 点群アナライザー | View, edit, and analyze point cloud data |
関数
ブロック
 | Point Cloud Viewer | Visualize streaming point cloud data sequence (R2023a 以降) |
トピック
- LiDAR の概要
LiDAR の概念および用途のおおまかな概要。
- Coordinate Systems in Point Cloud Toolbox
Overview of coordinate systems in Point Cloud Toolbox™.
- オーガナイズド点群とアンオーガナイズド点群とは
アンオーガナイズド点群およびオーガナイズド点群の定義と前者を後者に変換する方法。
- The PLY Format
The Stanford Triangle Format.
- Choose a Point Cloud Viewer
Compare visualization functions.
- Overview of Large Point Cloud Processing
Understand block processing for large point clouds that do not fit in memory.
注目の例
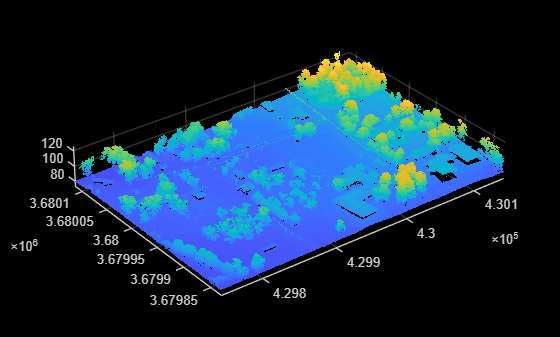
LAZ ファイルからの点群データの読み取り
LAZ ファイルから点群データおよびヘッダー情報を読み取るために使用する lasFileReader オブジェクトを作成します。

rosbag ファイルからの LiDAR とカメラのデータの読み取り
この例では、rosbag ファイルからイメージと点群のデータを読み取って保存する方法を示します。また、この例では LiDAR カメラ キャリブレーション用にデータを準備する方法も示します。
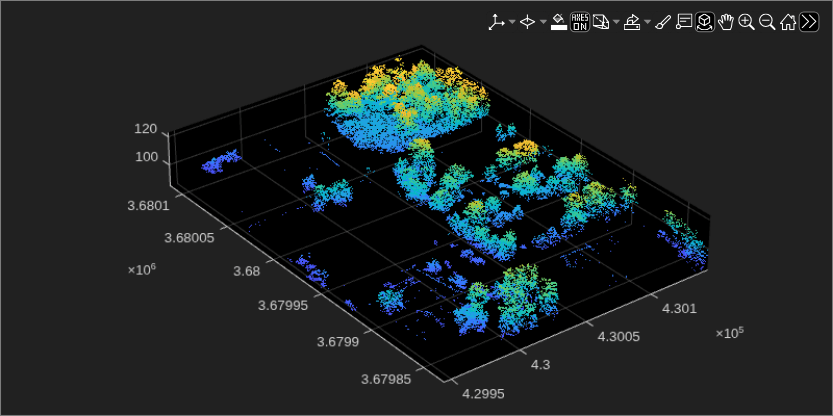
LiDAR 点群データの読み取り、処理、書き込み
この例では、点群をワークスペースに読み取り、目的の点集合を選択して、選択された点を点群ファイルの形式に書き込む方法を示します。
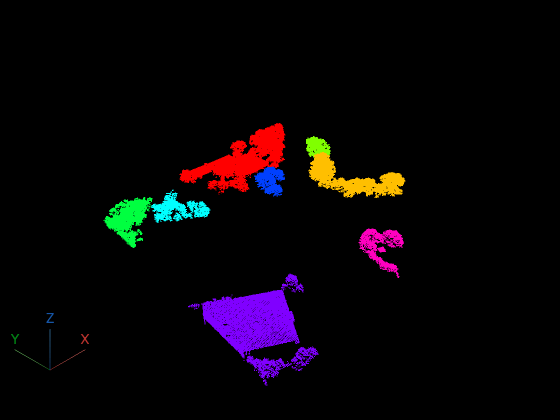
Color Point Clouds in pcviewer
Control point cloud coloring in pcviewer. You will learn how to:
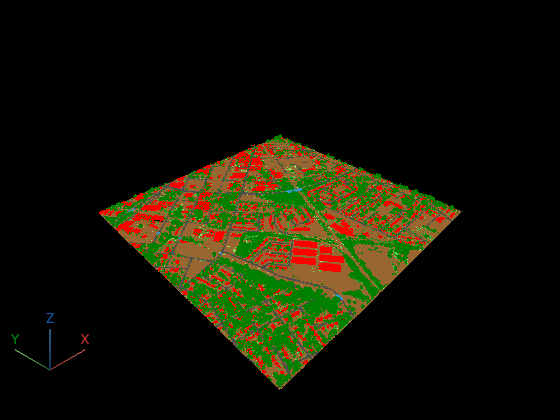
Visualize LAS Classification Labels
Read classification attributes from a LAS file and color the point cloud by class in pcviewer. Point cloud data from collection methods like aerial surveys often includes per-point classification labels (ground, vegetation, buildings) following the ASPRS standard.
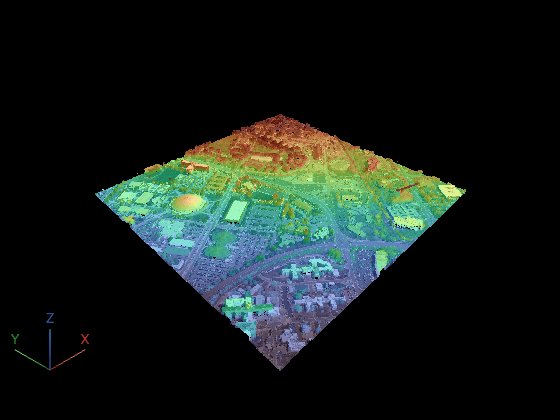
Color Point Clouds by Point Properties
Use per-point properties from a lidar point cloud to color the visualization in pcviewer. Coloring by point properties helps you identify patterns that are not visible in raw XYZ or RGB data, such as surface roughness, vegetation penetration, and acquisition geometry. The example demonstrates coloring by density, curvature, distance to ground, laser return number, scan angle, and elevation blending.
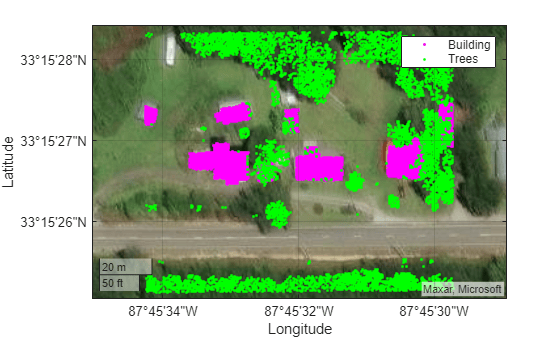
Export Point Cloud Segmentations to KML Files
Export segmented point cloud data to Keyhole Markup Language (KML) files and read and visualize the KML data using different tools.
Publish and Receive Point Cloud ROS Messages
Work with point cloud ROS messages and deploy them as a ROS node using MATLAB®.

