Extended and Hierarchical Multiplexing in CAN Messages
R2026bIntroduction
This example shows how to decode a CAN message that contains signals mutliplexed using extended and hierarchical multiplexing.
Extended and hierarchical multiplexing provide more flexibility than simple multiplexing in organizing signals in a CAN message. For instance, one CAN message can carry more than one multiplexor signal; signals can be multiplexed by multiple multiplexor values; and a signal can be both multiplexed and multiplexor, effectively introducing a signal hierarchy.
Consider the CAN message named PowerTrainTires available in the DBC file CAN_PowerTrainTires.dbc. Leveraging extended multiplexing, the message packs a large number of signals in a payload of 4 bytes. The byte order is Little Endian and the bit counting is LSb first for all signals. The signal hierarchies and bit layout are represented in the following figure.
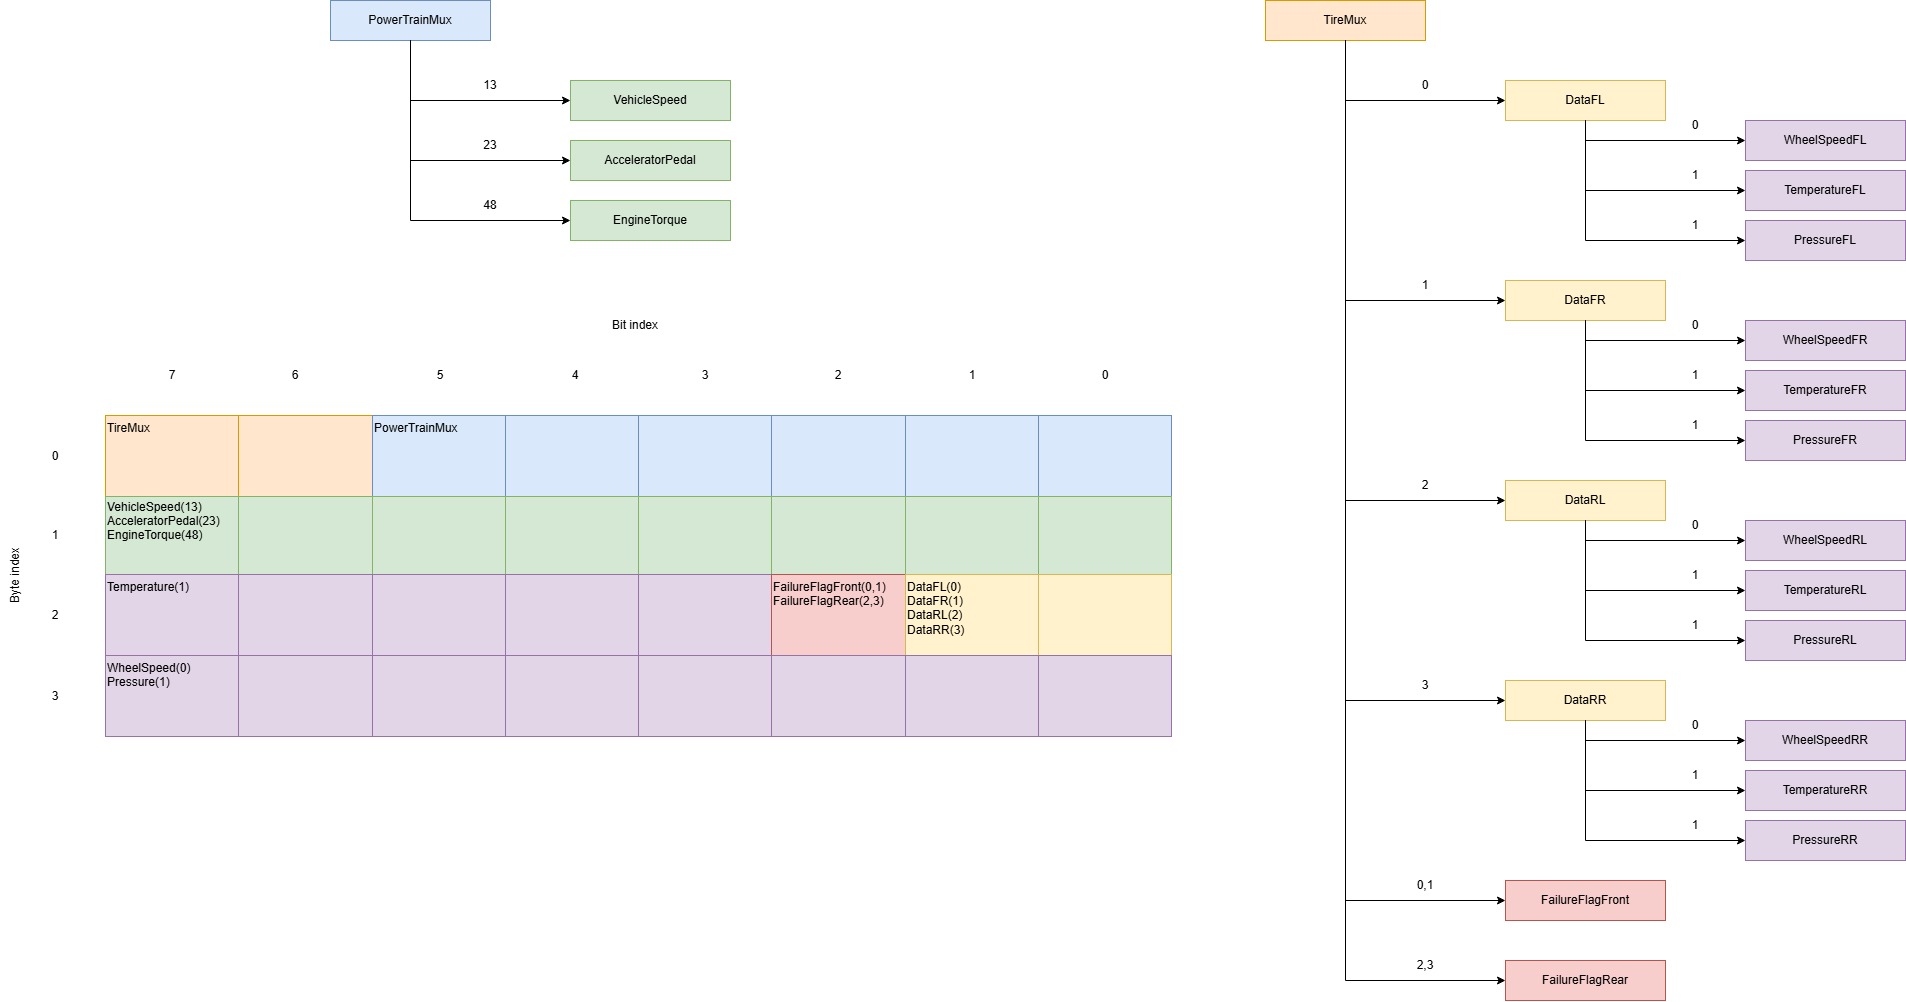
The figure displays signals with overlapping bit locations with the same color. Multiplexor values corresponding to each multiplexed signals are indicated above the arrow connecting a multiplexor to its hierarchy; the same values are repeated in the bit layout, in brackets after the signal names. In the bit layout, the signal names are positioned at their respective MSb.
The message is organized as follows:
Byte 0 store two multiplexors, namely,
PowerTrainMux(bits 0-5) andTireMux(bits 6-7); these are the main multiplexor at the top of their respective hierarchy.The
PowerTrainMuxsignal multiplexes theVehicleSpeed,AcceleratorPedalandEngineTorquesignals; these signals all share the same bit locations, that span byte 1.The
TireMuxsignal multiplexes the four different signalsDataFL,DataFR,DataRL,DataRR, which are themselves multiplexors for the data of the front left, front right, rear left and rear right wheels and tires, respectively.Valid values for the
TireMuxsignal are {0, 1, 2, 3}, mapping to the corresponding wheel position as shown in the hierarchy.Valid values for
DataFL,DataFR,DataRL,DataRRsignals are {0, 1}, where 0 maps to theWheelSpeedof the corresponding wheel, while 1 maps to measurements ofPressureandTemperatureof its tire.In the bit layout, the
WheelSpeedsignals span bits 3 to 7 of byte 2, and the entire byte 3, for a total of 13 bits. In contrast, theTemperatureandPressuresignals share those 13 bits, withTemperaturespanning bits 3 to 7 of byte 2, whilePressurespanning the entire byte 3.Bit 2 of byte 2 stores a boolean flag that indicates a combined failure status of the front or rear sensors. Therefore,
FailureFlagFrontis active only whenTireMuxis either 0 or 1 (front wheels) whileFailureFlagRearis active only whenTireMuxis either 2 or 3 (rear wheels).
Extended and Hierarchical Multiplexing Information in the CAN Database
The CAN database file is loaded using the canDatabase function. Extract the SignalInfo property in a separate variable.
db = canDatabase("CAN_PowerTrainTires.dbc");
signalInfo = db.MessageInfo.SignalInfo;
Inspect the contents of the structure for the PowerTrainMux signal. In this case, the signal metadata indicate that the signal is a multiplexor, the Multiplexor flag being equal to 1.
signalInfo(strcmp({signalInfo.Name}, 'PowerTrainMux'))ans = struct with fields:
Name: 'PowerTrainMux'
Comment: ''
StartBit: 0
SignalSize: 6
ByteOrder: 'LittleEndian'
Signed: 0
ValueType: 'Integer'
Class: 'uint8'
Factor: 1
Offset: 0
Minimum: 0
Maximum: 0
Units: ''
ValueTable: [0×1 struct]
Multiplexor: 1
Multiplexed: 0
MultiplexMode: 0
MultiplexorName: ''
RxNodes: {0×1 cell}
Attributes: {}
AttributeInfo: [0×0 struct]
The AcceleratorPedal signal metadata show instead that the signal is multiplexed, the Multiplexed flag being equal to 1; it also shows the name of its multiplexor (in this case, PowerTrainMux) in the MultiplexorName field. The MultiplexMode field carries the value of PowerTrainMux for which AcceleratorPedal is active.
signalInfo(strcmp({signalInfo.Name}, 'AcceleratorPedal'))ans = struct with fields:
Name: 'AcceleratorPedal'
Comment: ''
StartBit: 8
SignalSize: 8
ByteOrder: 'LittleEndian'
Signed: 0
ValueType: 'Integer'
Class: 'uint8'
Factor: 1
Offset: 0
Minimum: 0
Maximum: 0
Units: ''
ValueTable: [0×1 struct]
Multiplexor: 0
Multiplexed: 1
MultiplexMode: 23
MultiplexorName: 'PowerTrainMux'
RxNodes: {0×1 cell}
Attributes: {}
AttributeInfo: [0×0 struct]
In the case of the FailureFlagFront signal, the MultiplexMode field carries multiple values (in this case, 0 and 1) in a row vector.
signalInfo(strcmp({signalInfo.Name}, 'FailureFlagFront'))ans = struct with fields:
Name: 'FailureFlagFront'
Comment: ''
StartBit: 18
SignalSize: 1
ByteOrder: 'LittleEndian'
Signed: 0
ValueType: 'Integer'
Class: 'uint8'
Factor: 1
Offset: 0
Minimum: 0
Maximum: 0
Units: ''
ValueTable: [0×1 struct]
Multiplexor: 0
Multiplexed: 1
MultiplexMode: [0 1]
MultiplexorName: 'TireMux'
RxNodes: {0×1 cell}
Attributes: {}
AttributeInfo: [0×0 struct]
The metadata of DataFL show that this signal is both multiplexor and multiplexed, the Multiplexor and Multiplexed flags being both equal to 1.
signalInfo(strcmp({signalInfo.Name}, 'DataFL'))ans = struct with fields:
Name: 'DataFL'
Comment: ''
StartBit: 16
SignalSize: 2
ByteOrder: 'LittleEndian'
Signed: 0
ValueType: 'Integer'
Class: 'uint8'
Factor: 1
Offset: 0
Minimum: 0
Maximum: 0
Units: ''
ValueTable: [0×1 struct]
Multiplexor: 1
Multiplexed: 1
MultiplexMode: 0
MultiplexorName: 'TireMux'
RxNodes: {0×1 cell}
Attributes: {}
AttributeInfo: [0×0 struct]
Data Decoding and Visualization
The data file testDriveData.blf contains a log of the CAN message PowerTrainTires. Read the log using the blfread function.
data = blfread("testDriveData.blf");The data is in the form of a CAN message timetable; decode it using the database provided.
msgTT = canMessageTimetable(data{1}, db);Inspect the first element of the Signals column.
msgTT.Signals{1}ans = struct with fields:
FailureFlagRear: NaN
FailureFlagFront: 0
PressureRR: NaN
PressureRL: NaN
PressureFR: NaN
PressureFL: NaN
TemperatureRR: NaN
TemperatureRL: NaN
TemperatureFR: NaN
TemperatureFL: NaN
WheelSpeedRR: NaN
WheelSpeedRL: NaN
WheelSpeedFR: NaN
WheelSpeedFL: 0
DataRR: NaN
DataRL: NaN
DataFR: NaN
DataFL: 0
VehicleSpeed: NaN
EngineTorque: NaN
AcceleratorPedal: 0
TireMux: 0
PowerTrainMux: 23
The structure contains the values of all the active signals at that time instant; signals that are inactive have values that are effectively missing, and thus are assigned a value of NaN. At the first time instant, the PowerTrainMux and TireMux values indicate that AcceleratorPedal is active as well as the data from the front left wheel; in addition, the DataFL value indicates that the WheelSpeedFL is active; all the other wheel and tire signals are unavailable. Since data from one of the front wheels is available through the WheelSpeedFL signal, also the FailureFlagFront sensor signal is active.
It is convenient to create a signal timetable to facilitate the inspection and visualization of signal values.
sigTT = canSignalTimetable(msgTT);
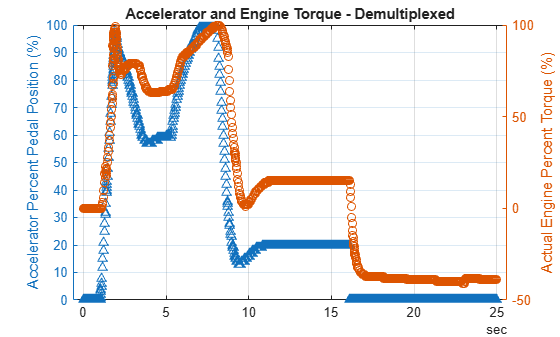
Visualize the AcceleratorPedal and EngineTorque signals after demultiplexing. Note that NaN values are not displayed.
figure;
yyaxis("left");
plot(sigTT.Time, sigTT.AcceleratorPedal, '^');
ylabel("Accelerator Percent Pedal Position (%)")
yyaxis("right");
plot(sigTT.Time, sigTT.EngineTorque, 'o');
grid("on");
ylabel("Actual Engine Percent Torque (%)");
title("Accelerator and Engine Torque - Demultiplexed");
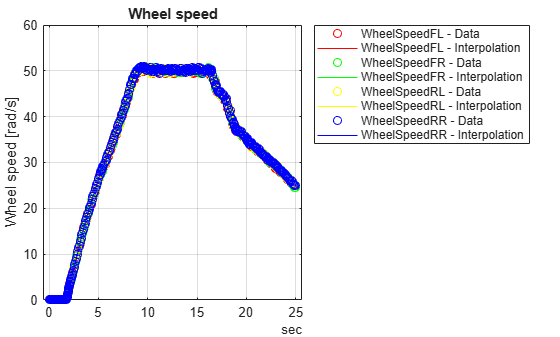
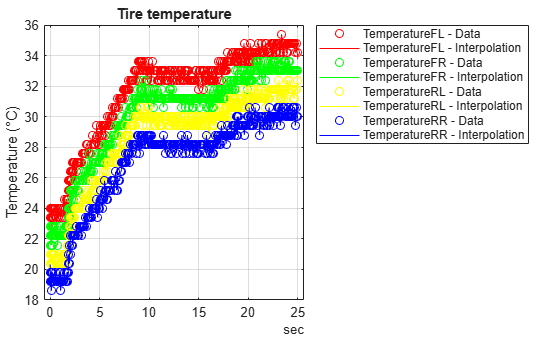
Visualize the demultiplexed WheelSpeed, Temperature and Pressure signals for the four wheels. Due to multiplexing, the recorded log has a large number of missing data; markers are used to identify the data, while linear interpolation is used to fill in the gaps.
figure;
plot(sigTT.Time, sigTT.WheelSpeedFL, 'ro');
hold('on');
plot(sigTT.Time, fillmissing(sigTT.WheelSpeedFL, "linear"), 'r-');
plot(sigTT.Time, sigTT.WheelSpeedFR, 'go');
plot(sigTT.Time, fillmissing(sigTT.WheelSpeedFR, "linear"), 'g-');
plot(sigTT.Time, sigTT.WheelSpeedRL, 'yo');
plot(sigTT.Time, fillmissing(sigTT.WheelSpeedRL, "linear"), 'y-');
plot(sigTT.Time, sigTT.WheelSpeedRR, 'bo');
plot(sigTT.Time, fillmissing(sigTT.WheelSpeedRR, "linear"), 'b-');
grid('on');
ylabel("Wheel speed [rad/s]");
legend("WheelSpeedFL - Data", "WheelSpeedFL - Interpolation", ...
    "WheelSpeedFR - Data", "WheelSpeedFR - Interpolation", ...
    "WheelSpeedRL - Data", "WheelSpeedRL - Interpolation", ...
    "WheelSpeedRR - Data", "WheelSpeedRR - Interpolation", "location", "bestoutside");
title("Wheel speed");
figure;
plot(sigTT.Time, sigTT.TemperatureFL, 'ro');
hold('on');
plot(sigTT.Time, fillmissing(sigTT.TemperatureFL, "linear"), 'r-');
plot(sigTT.Time, sigTT.TemperatureFR, 'go');
plot(sigTT.Time, fillmissing(sigTT.TemperatureFR, "linear"), 'g-');
plot(sigTT.Time, sigTT.TemperatureRL, 'yo');
plot(sigTT.Time, fillmissing(sigTT.TemperatureRL, "linear"), 'y-');
plot(sigTT.Time, sigTT.TemperatureRR, 'bo');
plot(sigTT.Time, fillmissing(sigTT.TemperatureRR, "linear"), 'b-');
grid('on');
ylabel("Temperature (°C)");
legend("TemperatureFL - Data", "TemperatureFL - Interpolation", ...
    "TemperatureFR - Data", "TemperatureFR - Interpolation", ...
    "TemperatureRL - Data", "TemperatureRL - Interpolation", ...
    "TemperatureRR - Data", "TemperatureRR - Interpolation", "Location", "bestoutside");
title("Tire temperature");
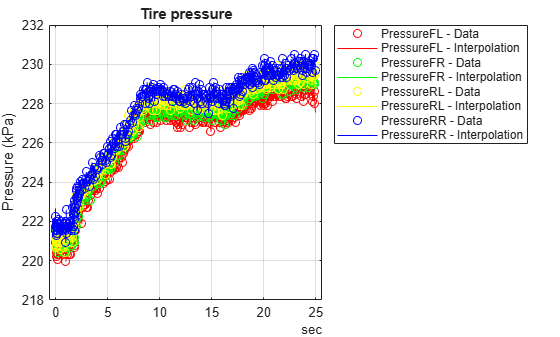
figure;
plot(sigTT.Time, sigTT.PressureFL, 'ro');
hold('on');
plot(sigTT.Time, fillmissing(sigTT.PressureFL, "linear"), 'r-');
plot(sigTT.Time, sigTT.PressureFR, 'go');
plot(sigTT.Time, fillmissing(sigTT.PressureFR, "linear"), 'g-');
plot(sigTT.Time, sigTT.PressureRL, 'yo');
plot(sigTT.Time, fillmissing(sigTT.PressureRL, "linear"), 'y-');
plot(sigTT.Time, sigTT.PressureRR, 'bo');
plot(sigTT.Time, fillmissing(sigTT.PressureRR, "linear"), 'b-');
grid('on');
ylabel("Pressure (kPa)");
legend("PressureFL - Data", "PressureFL - Interpolation", ...
    "PressureFR - Data", "PressureFR - Interpolation", ...
    "PressureRL - Data", "PressureRL - Interpolation", ...
    "PressureRR - Data", "PressureRR - Interpolation", "location", "bestoutside");
title("Tire pressure");