このページの内容は最新ではありません。最新版の英語を参照するには、ここをクリックします。
モーター、サーボ モーター、モーター ドライバー
R2026a幅広い用途向けのロバストなモーター制御システムを実装するための、モーター、サーボ モーター、モーター ドライバーをもつ Simulink® モデルを構成して設計します。
ブロック
 | Servo Write | Set servo motor to specified angle |
 | M1M2DCMotors | Control power and direction of DC motor on port M1 or M2 |
 | M3M4DCMotors | Control power and direction of DC motor on port M3 or M4 |
 | Encoder | Measure rotation of motor in ticks |
 | Battery Read | Read voltage of battery |
 | L293D DC Motor | Control power and direction of a DC motor (R2023a 以降) |
 | PCA9685 DC Motor | Control power and direction of a DC motor (R2023a 以降) |
 | Continuous Servo Write | Set direction and speed of continuous rotation servo motor |
 | Standard Servo Read | Measure shaft position of standard servo motor in degrees |
 | Standard Servo Write | Set shaft position of standard servo motor to angle specified in degrees |
トピック
- Use Arduino Engineering Kit Rev 2 with Preconfigured Projects in Support Package
Learn how to use Arduino® Engineering Kit Rev 2 with the support package.
注目の例
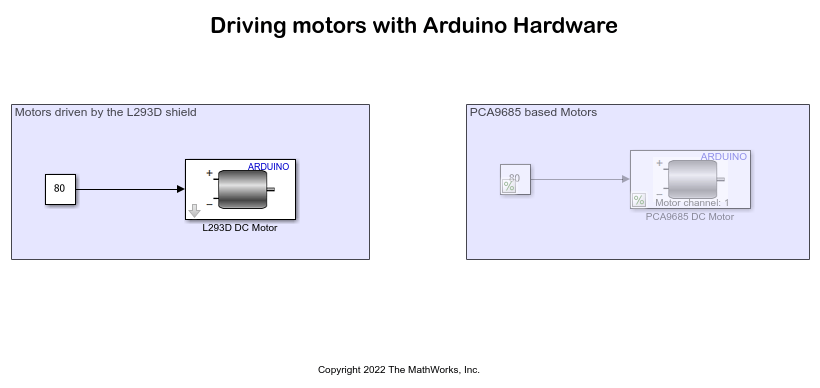
Get Started with Motor Drives for Robotics Applications Using Arduino Hardware and Simulink
Use Simulink® Support Package for Arduino® Hardware and an Arduino hardware board to get started with interfacing the motor drives for robotics applications.
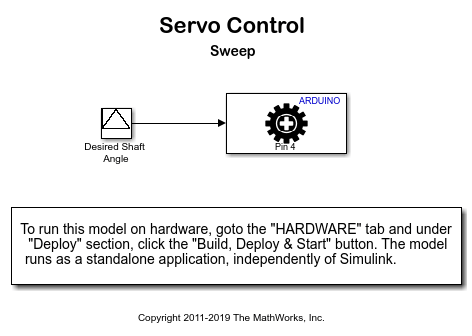
Control Standard Servo Motor Using Arduino Hardware
Use Simulink® Support Package for Arduino® Hardware to control a standard servo motor.

Self-Balancing Motor Cycle Using Arduino Engineering Kit Rev 2
Use Arduino® Engineering Kit Rev 2 to build and program a motorcycle bot that self-balances and maneuvers by itself using a flywheel. The project models the motorcycle with the help of inverted pendulum dynamics and performs inertial sensing to balance the motorcycle by controlling the flywheel, located at the center of the motorcycle.
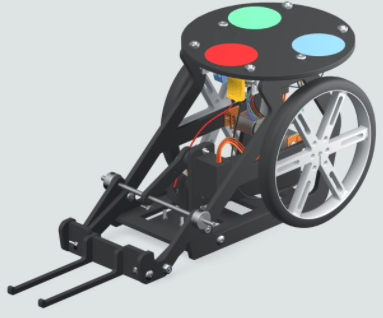
Webcam Controlled Rover Using Arduino Engineering Kit Rev 2
Use Arduino® Engineering Kit Rev 2 to program a differential drive robot that can be remotely controlled by MATLAB® over Wi-Fi® to perform operations such as path following and moving objects with a forklift along with obstacle avoidance.
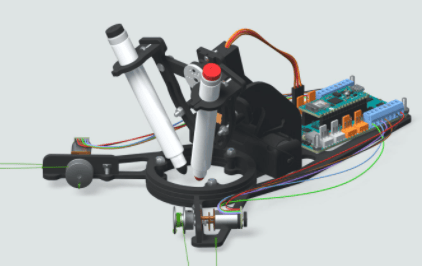
Drawing Robot Using Arduino Engineering Kit Rev 2
Use Arduino® Engineering Kit Rev 2 to build and program a robot that extracts line traces from an image and reproduces it as a drawing on a whiteboard. The project uses MATLAB® code to capture an image using a webcam, and then convert it into a set of motor commands using image processing techniques, which drive the robot across a whiteboard and reproduce the captured image as a drawing.
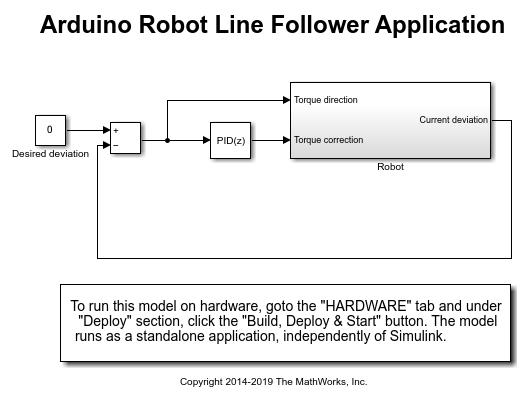
Line Follower Application for Arduino Robot
Create a line follower algorithm in Simulink® and how to run it on an Arduino® Robot.
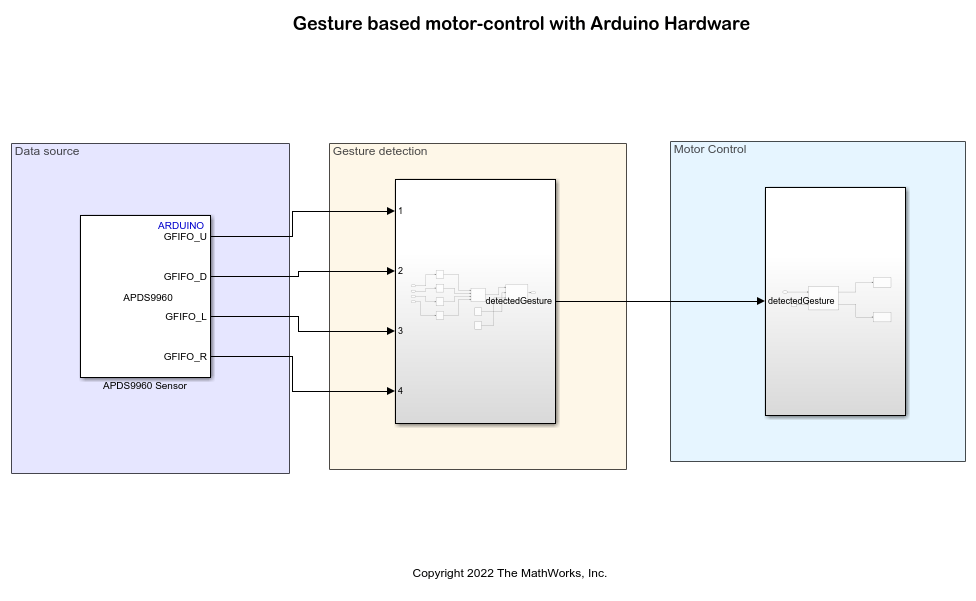
Develop Gesture Based Motor-Control Robot Using Arduino and Simulink
Use Simulink® Support Package for Arduino® Hardware and an Arduino hardware board to develop gesture based motor-control robot.
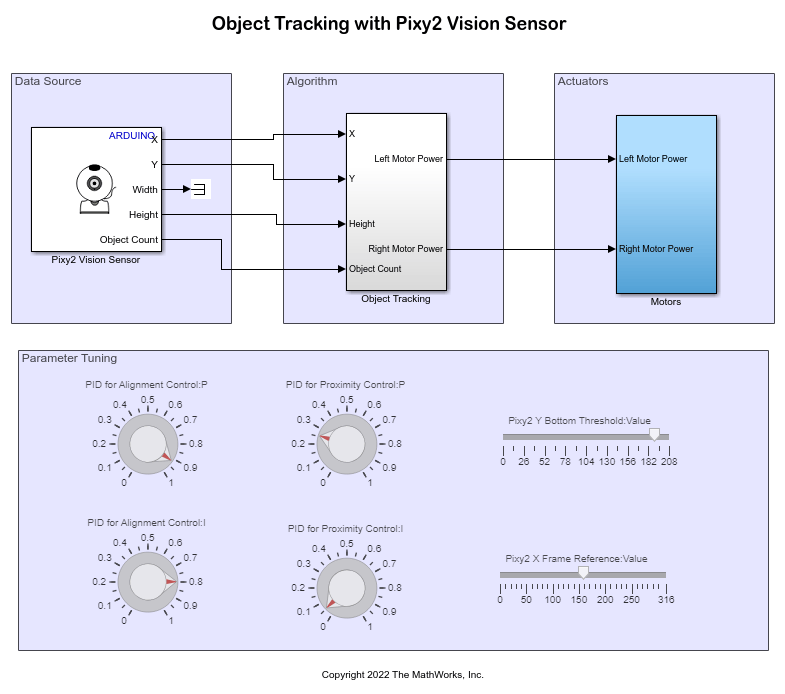
Develop Object Tracking Robot Using Arduino Hardware and Simulink
Use Simulink® Support Package for Arduino® Hardware and an Arduino hardware board to develop object tracking robot.

